Multi-branch harnesses
Integrate sensor, I/O and control branches with defined breakout positions, lengths, labels and connector cavities.
ROBOTICS & AUTOMATION
Connect your robot.
Define the motion.
Build-to-print power, feedback, sensor and control harnesses for robotics OEMs and automation integrators. Manufactured to your approved drawings, components and inspection requirements.
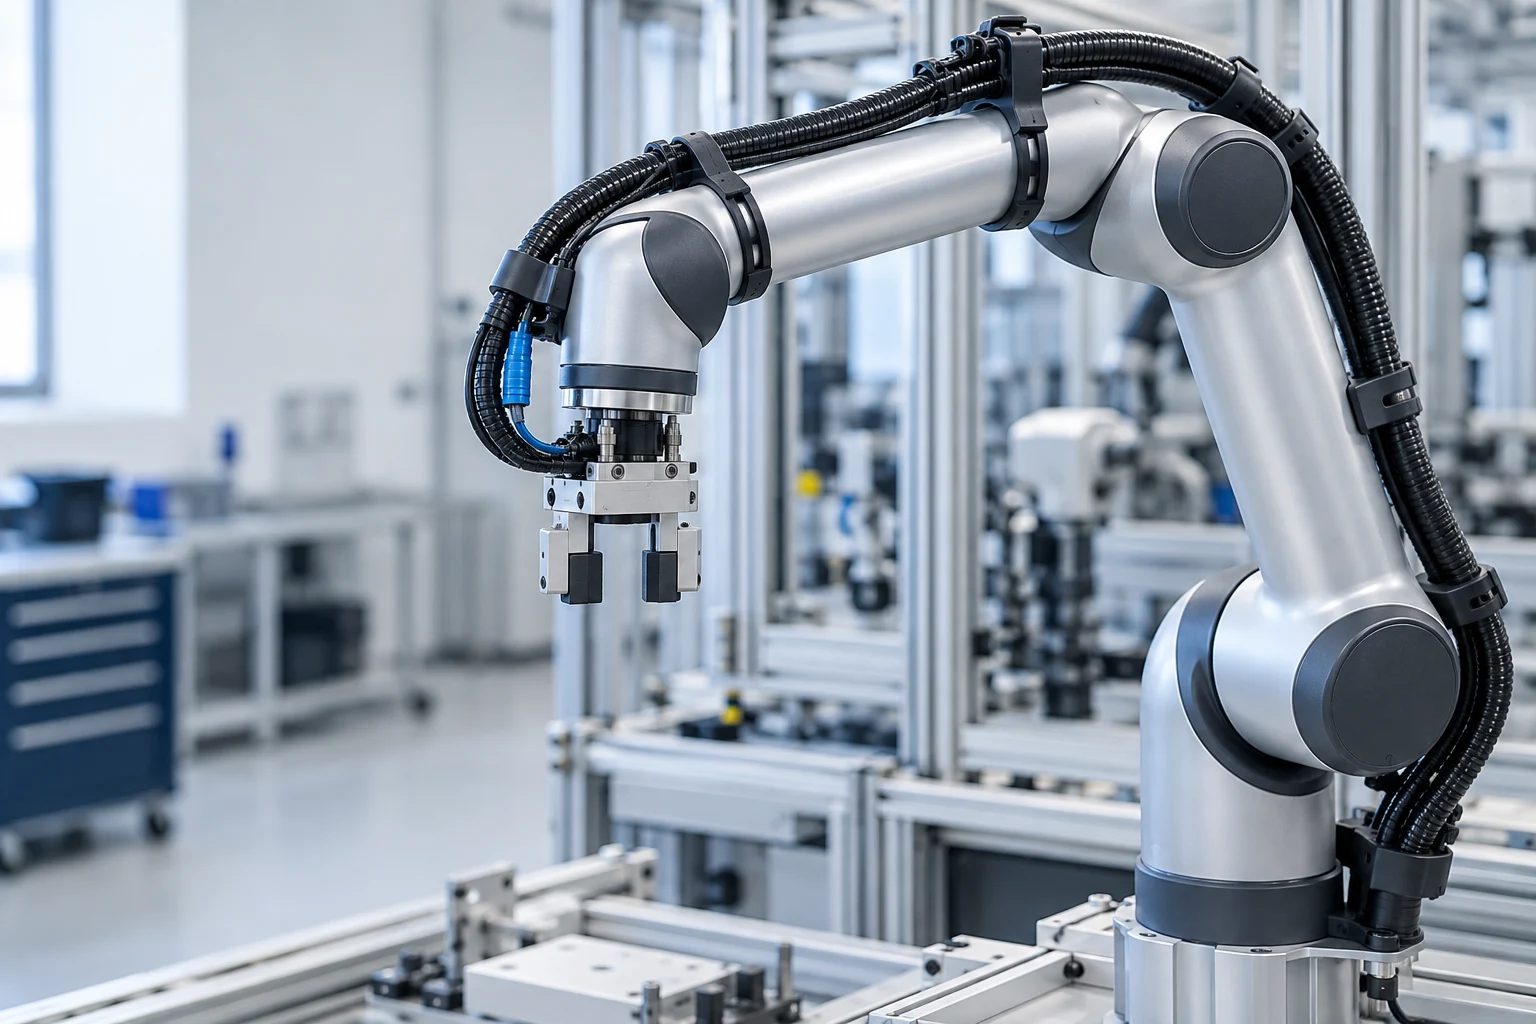
From controller to end effector.
ONE ROBOT. DIFFERENT CONNECTIONS.
A robotics cable assembly connects the robot’s electrical components with specified cable, connectors, terminations and protection. A wire harness can combine several branches into one organized installation.
The right configuration depends on where it runs, what it carries and how it moves.
START WITH THE MOVEMENT
Describe the motion before selecting the construction. A cable that bends easily by hand is not automatically suitable for continuous flexing or robot torsion.
For wiring within a controller, robot base or stationary machine section, define the installation bend radius, clearances, fastening points and service loop.
Add this motion type to my enquiry
Motion type added to the project form.
Use the cable supplier’s limits for the selected part number. Confirm the assembly and routing in the actual motion profile; no universal bend radius, torsion angle or cycle life is assumed.
ASSEMBLY OPTIONS
Choose the circuit layout, connector system and protection together. The examples below show available assembly structures.
Integrate sensor, I/O and control branches with defined breakout positions, lengths, labels and connector cavities.
Specified board, panel and device interfaces, with circuit verification and shield termination where required.
Review cable-exit direction, jacket compatibility and strain relief against the connector, tooling and installation.
THE ROBOTICS RFQ
Include the drawing revision and exact component references. Flag open questions so the quotation identifies what still needs approval.
| Requirement | Information to provide | Review focus |
|---|---|---|
| Electrical load | Voltage, current per circuit, conductor size, grounding and equipment interfaces. | Wire, contact and connector compatibility; specified insulation and termination requirements. |
| Motion profile | Bending or torsion, travel, speed, acceleration, duty cycle and required service life. | Cable construction, supplier motion ratings and the agreed application validation plan. |
| Routing & dimensions | Overall and branch lengths, tolerances, bend clearances, fixing points and connector clocking. | Assembly fit, slack, strain relief, tool access and separation from moving parts. |
| Signal & shielding | Interface specification, pair assignment, shield continuity and grounding arrangement. | Shield preparation, termination and test criteria. EMC or network performance requires defined validation. |
| Environment | Temperature, abrasion, vibration, oil, coolant, cleaning agents and required sealing. | Selected jacket, sleeves, connectors and molded transitions; exposure-specific evidence. |
| Acceptance & records | Inspection methods, limits, sampling, identification, revision and required documentation. | Manufacturing checks, first-article approval and any additional qualification arrangements. |
Connector brands identify specified components. Confirm exact part numbers, mating parts and the approved sourcing route.
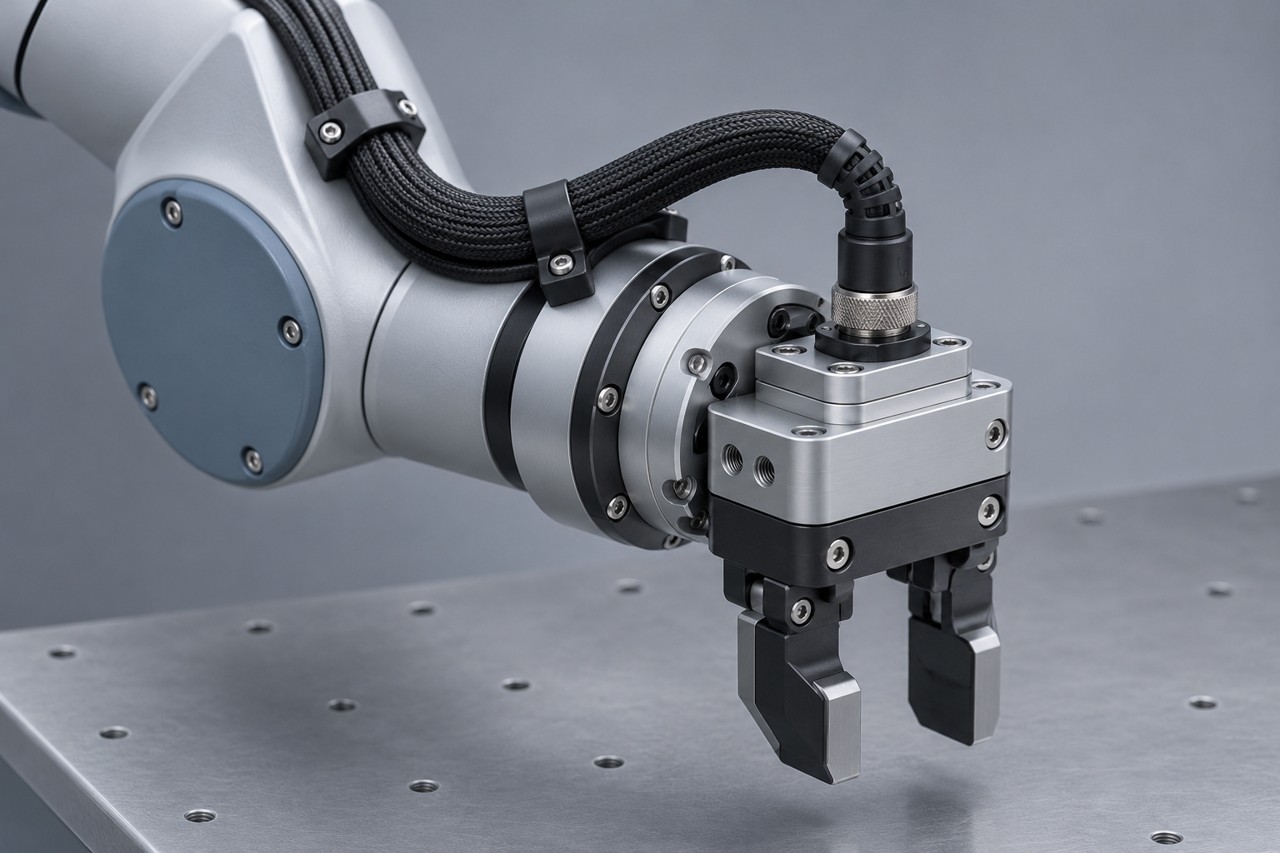
FROM DRAWING TO REPEAT BUILD
Check the BOM, pinout, motion route, component availability and inspection requirements before agreeing the manufacturing route.
Prepare and terminate wires, assemble the connectors, route branches and apply specified protection. Review fit and agreed inspection results.
Resolve changes, freeze the revision and document the approved configuration for pilot or repeat production.
INSPECTION & VALIDATION
Manufacturing inspection verifies the approved build. Robot motion, service life and equipment performance need a defined qualification plan.
Agree the connection map, continuity and wire-sequence checks. Define DC resistance or other electrical tests where required.
Review crimp pull-force or cross-section checks as appropriate, contact seating, connector orientation, branch lengths and markings.
Set the bend radius, torsion, speed, load, environment and failure criteria for any flex-life test. Confirm the test arrangement before committing to a performance claim.
XSD documents ISO 9001 and IATF 16949 quality systems. These do not certify a robot’s functional safety or establish a cable’s dynamic life.
ENGINEERING & SOURCING QUESTIONS
Answers for a clearer robotics cable assembly RFQ.
Send the drawing, BOM, connector and terminal part numbers, pinout, dimensions, quantity and inspection criteria. For moving routes, add the motion profile, installed bend radius, torsion angle over free cable length, environment and validation requirements.
Do not assume it can. Repeated bending and multi-axis torsion place different demands on cable construction. Check the selected part’s ratings for the actual motion and confirm the installed routing and test conditions.
A cycle-life commitment requires a defined cable, termination, route, bend radius, torsion, speed, temperature and failure criterion, supported by applicable test evidence. This page does not state a universal flex-cycle rating.
Send the exact housing, contact, seal and mating-interface references for review. Confirm cable compatibility, keying, pin assignment and clocking. Brand names or connector appearance alone are insufficient.
Specified communication assemblies can be reviewed against the cable and connector system. Identify the protocol, cable category, pair map, shielding and acceptance tests. Bandwidth or protocol certification is not inferred from a completed continuity test.
Overmolding can provide strain relief and protection. A sealing claim depends on the complete connector, cable exit, materials, mating condition and agreed ingress test. Define the target before choosing the construction.
Prototype and pilot requirements can be reviewed before production release. Component availability, tooling, first-article inspection and customer approval determine the build plan, minimum quantity and lead time.
No. Manufacture to an approved wiring specification does not establish functional safety or equipment-level compliance. The robot or machine manufacturer must define safety-related requirements, validation and system release.
LET’S REVIEW YOUR CONNECTIONS
Share the available specifications and identify what still needs to be defined. We’ll review the components, manufacturing route and inspection scope.
Drawing & BOM · Pinout · Cable and connector references · Route and branch lengths · Motion profile · Environment · Quantity · Acceptance criteria